The IEEE International Conference on Robotics and Automation (ICRA) was held from 20-24 May 2019 at The Palais des congrès de Montréal in Canada, and it is the IEEE Robotics and Automation Society’s flagship conference. This year it received over 2900 submissions from 62 countries, from which a total of 1277 papers were finally accepted (44% acceptance rate).
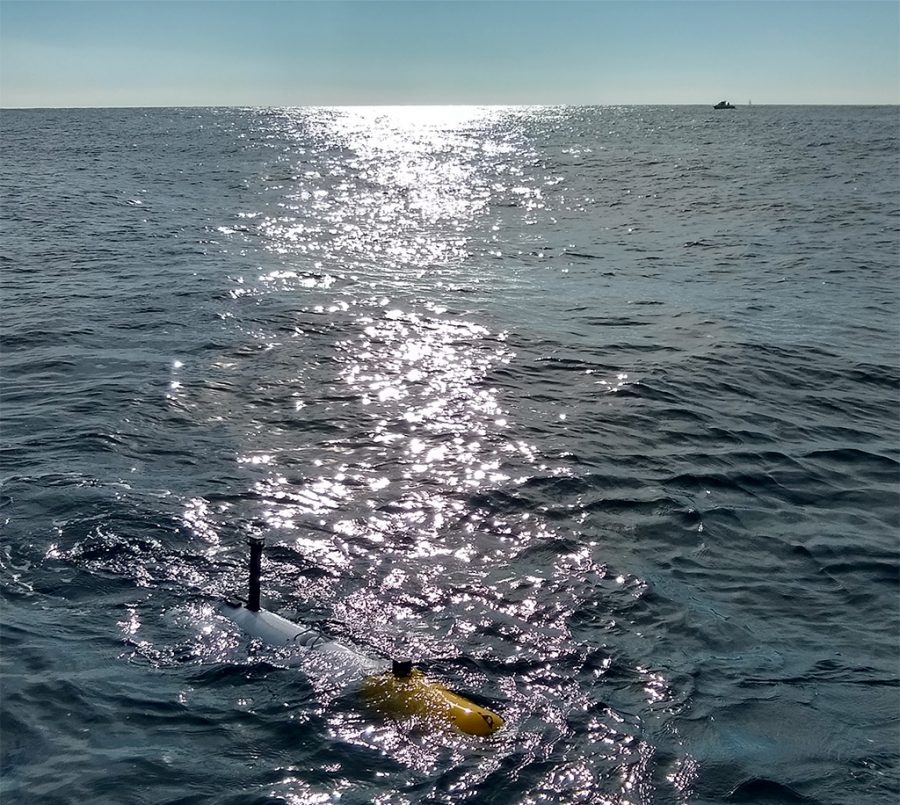
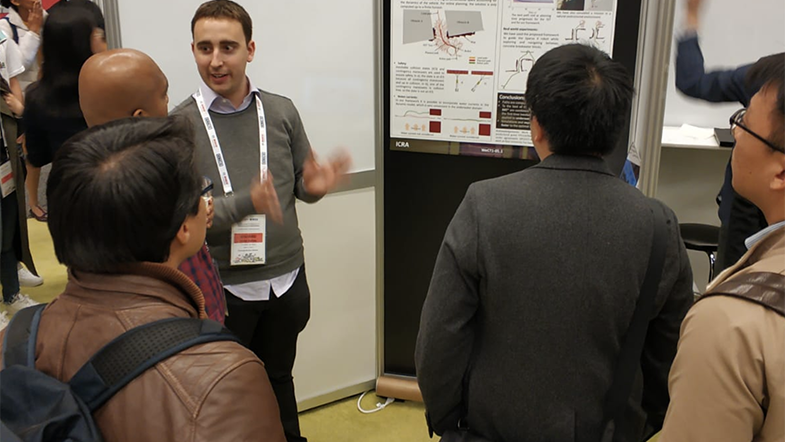
Eduard Vidal, a PhD student under the supervision of Dr. Marc Carreras, submitted a research paper reporting the results of his collaboration with Rice University and the Lydia Kavraki lab. The topic of his research is motion planning for autonomous underwater vehicles, focusing on systems with motion constraints and nonlinear dynamics, with applications in underwater exploration and view planning.
The paper was not only accepted for its presentation in the conference, but it was also selected as one of the three Best Student Paper Award Finalists, receiving very positive feedback from the community.
The article can be found in the conference proceedings as:
Eduard Vidal, Mark Moll, Narcís Palomeras, Juan David Hernández, Marc Carreras and Lydia E. Kavraki, “Online Multilayered Motion Planning with Dynamic Constraints for Autonomous Underwater Vehicles”, IEEE International Conference on Robotics and Automation (ICRA), 2019.