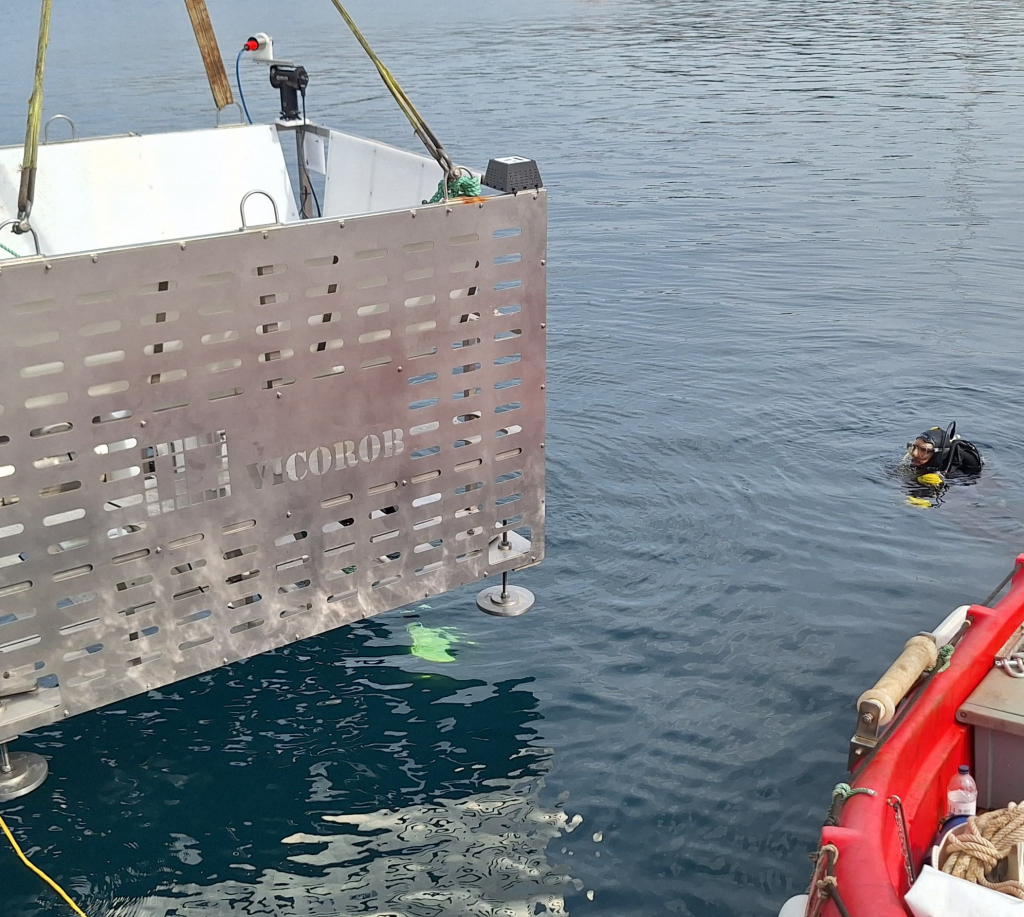
As a part of the PLOME project, we intend to develop a robust and reliable underwater solutions for long term deployment. In this experiment we deployed the Girona AUV docking station at Sant feliu de Guixols from 27 of May till 14 of June 2024. During this period we tested multiple systems. One of the main systems tested is the Autonomous docking maneuver.
Girona AUV docking station at Sant feliu de Guixols – ViCOROB
The target is to use the Girona AUV, to go in the Docking station and wait in it until the order to perform a mission is initiated. Then the Girona AUV will perform the following sequence of actions. First it needs to undock from the docking station. Second, perform a mission, which in our study was a scout mission for 3 min. Then to go back inside the docking station. All this process needs to be performed fully autonomous, without the interference of the engineers.