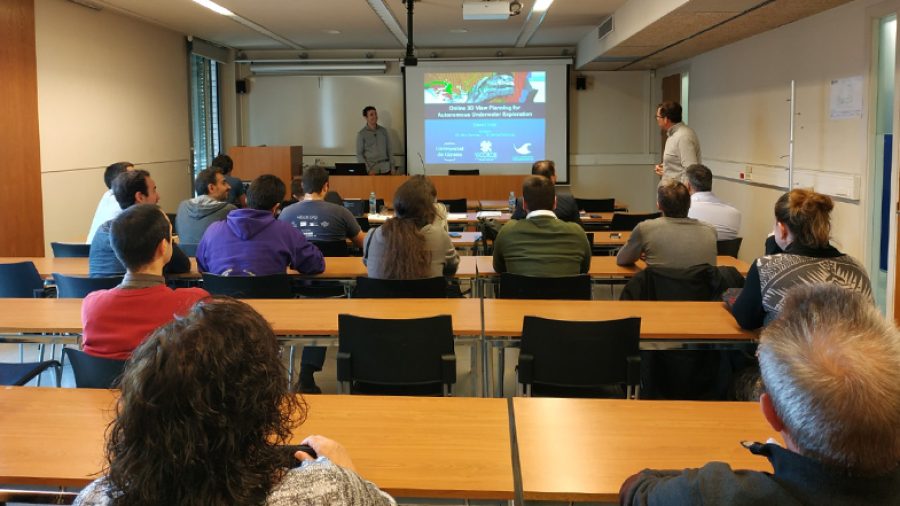
From the 13th of February until the 12th of March, Eduardo Soarez, an INES TEC pre doc researcher, has carried out a shot term scientific mission at CIRS facilities within the framework of Deepfield project.
The main focus of the short-term scientific missions is to engage INESC TEC young researchers in a assignment of a deep learning topic related to the previous thematic workshop, in which our case was related with Autonomous Underwater Intervention, celebrated on the 11 and 12th of February 2020. The overall objective of the mission is that the young researcher will a have a dedicated period of time to focus on learning and acquire knowledge in the designated topic and gain more insights and foundations on deep learning basics to continue their research. In the case of Eduardo Soarez, the purpose of the one-month stay was to gain knowledge related with robotics intervention and control.
We have asked him to share with us his experience by answering the questions below:
Which is the purpose of your stay at the University of Girona?
I’m at Vicorob within the scope of the project Deepfield, where UdG is one of the partners. The main goal of this project is to share experiences and knowledge between research labs.
Since both labs work on underwater robotics it’s good to have another perspective from people that deal with similar problems.
Why did you choose the University of Girona?
I have been working mainly on computer vision for underwater perception, but I also want to do some research on robotics control. And from all the partners of the project, the CIRS lab was the one where I would fit better because the lab has a lot of good work done on the control for interventions AUVs and also in computer vision.
Which results do you expect to have after your stay?
In the end, I’m expecting to have learned more about control for AUVs, for instance, like, what tools CIRS uses to control there AUVS? Is it the same as us? How do they control the AUVs?? And regarding intervention AUVs, that is the new area for me, what are the main problems or difficulties for a robot to perform a certain task?
And to have another work view, from people that have been working in the same area and share their experiences and research.
Would you like to repeat the experience?
So far it has been a very positive experience for me and the city is very pleasant to live in. So it would be very good to repeat it in the future, however, I don’t think that would be possible on this project =).