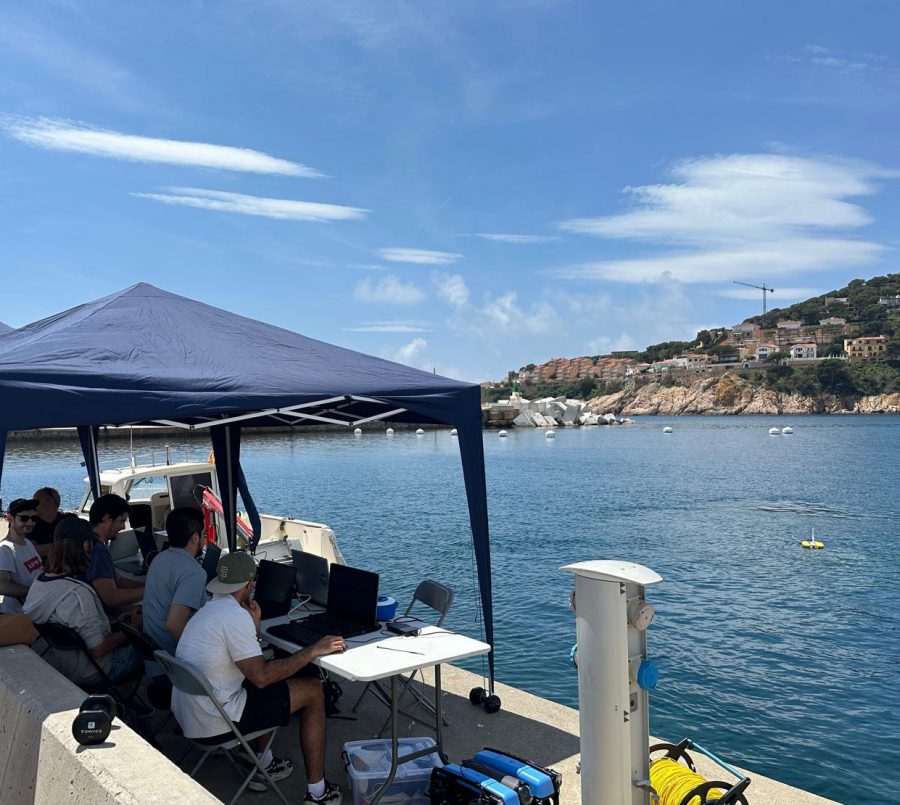
One of the principal research lines of the Underwater Vision and Robotics Laboratory of VICOROB institute is the “long-term deployment”. This research line has as its objective to advance the technology in order to achieve future permanent robotic fleets in strategic locations.
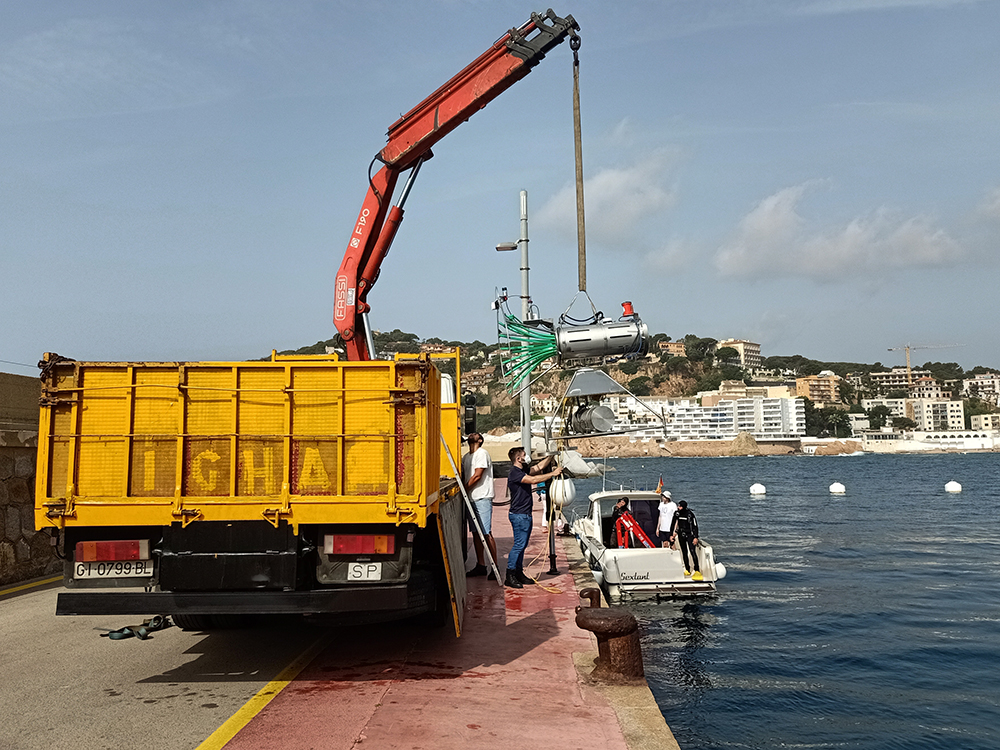
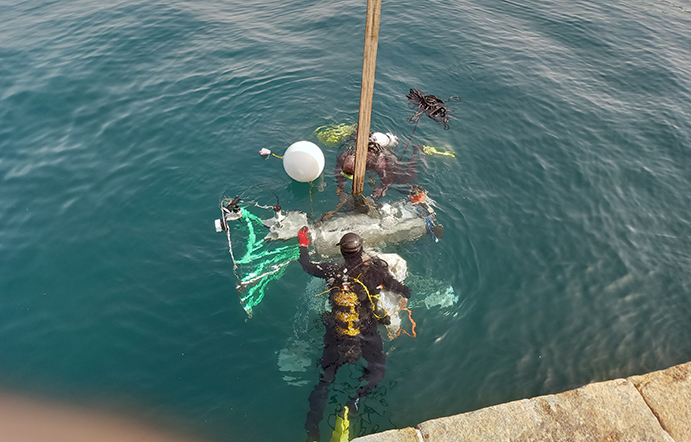
In the last months, it was sucesfully achieved, in an experimental way, the autonomous docking application using a non-holonomic robot on a prototype of an underwater docking station. First, it was designed and manufactured the docking station prototype. It was solved from a theoretical point of view the strategy algorithm and the controller needed in order to use a non-holonomic AUV, testing the results with numerical methods and simulation. The experimental application was developed relying only on acoustics in order to obtain a robust localization between the robot and the docking station.
These experiments were developed in the marine installations associated with the University of Girona with the objective of replying them in the installations on Viana do Castello (Portugal) in the frame of the ATLANTIS research project (The Atlantic Testing Platform for Maritime Robotics). With the future view of using these developed technologies in permanent robotic fleets dedicated to the autonomous maintenance of offshore installations, like wind farms.